Communication Protocols
From a top level view, the communication takes place between the processing module of the remote system and the mission control system (residing at the ground segment).
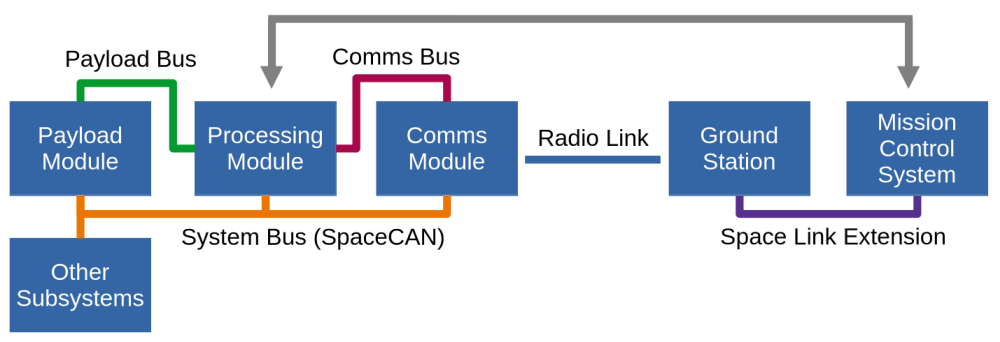
For example, let's follow the process of a user that want to switch the camera payload to capture images. The user issues the command, which will be transferred (as a telecommand) to the ground station and sent over radio link to the comms module. The telecommand the reaches the processing module through the comms bus. The processing module then executes the telecommand by issuing the respective service function through the system bus to the payload module (which is confirmed back through the system bus). The captured image data is transferred through the dedicated payload bus (to not block the system bus) to the processing module, which in turn forwards the data as telemetry to the comms module for transmission to ground. On the ground side, the ground station transfers the telemetry to the mission control system for further processing and/or storage.
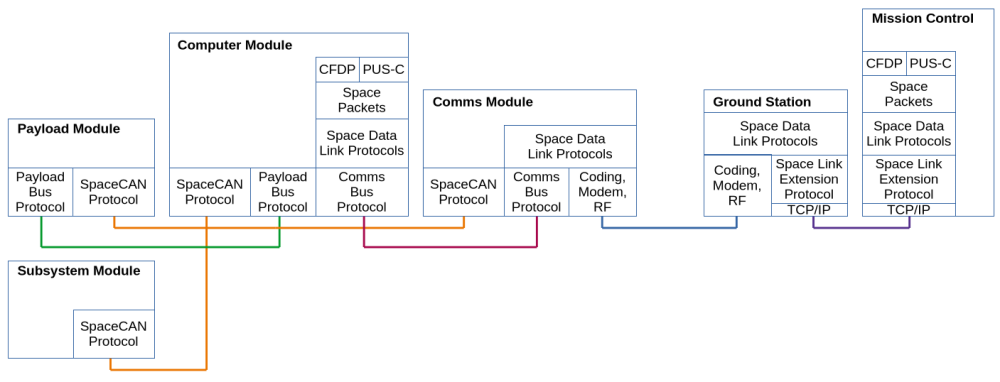
There a several protocols involved here, as shown in the figure below. They are described in the following sections in detail.
System Bus Protocol (SpaceCAN)
The purpose of the system bus is to provide the central processing unit (computer module) with control and monitoring capabilities over the other subsystem and payload modules. Data exchanged on this bus is of low to moderate quantity but must be transmitted in a reliable way. The bus is not intended to deliver high-volume data, such as science data. Instead, it shall ensure reliable and robust communication between controller and responder nodes of the network. For this, small messages are sent between nodes that must arrive without error and with minimum delay. We are using the SpaceCAN bus as the system bus, which is based on CAN bus.
Payload Bus Protocol
The computer module has a dedicated, redundant interface to the payload module for exchange of non-critical, high volume data. Typically, the payload generates lots of data (such as images from camera) and this data shall not be sent over the system bus, as it is not needed for monitoring and control of the system status. Such data will be sent of this dedicated, redundant UART bus. To protocol for data sending over this bus is TO BE DEFINED.
Comms Bus Protocol
To be written...
Space Data Link Protocols
To be written...
Space Packet Protocol
To be written...
CCSDS File Delivery Protocol (CFDP)
To be written...
ECSS Packet Utilization Protocol (PUS-C)
To be written...
https://ecss.nl/standard/ecss-e-st-70-41c-space-engineering-telemetry-and-telecommand-packet-utilization-15-april-2016/
Coding, Modem, RF
To be written...
Space Link Extension Protocol
To be written...
- Forward communications link transmission unit (FCLTU): provides CLTUs for uplink to the spacecraft
- Return all frames (RAF): provides the telemetry frames from a single space link symbol stream
- Return channel frames (RCF): provides master channel (MC) or specific virtual channels (VC)
- Return operational control field (ROCF): provides MC or VC operational control fields (OCFs)